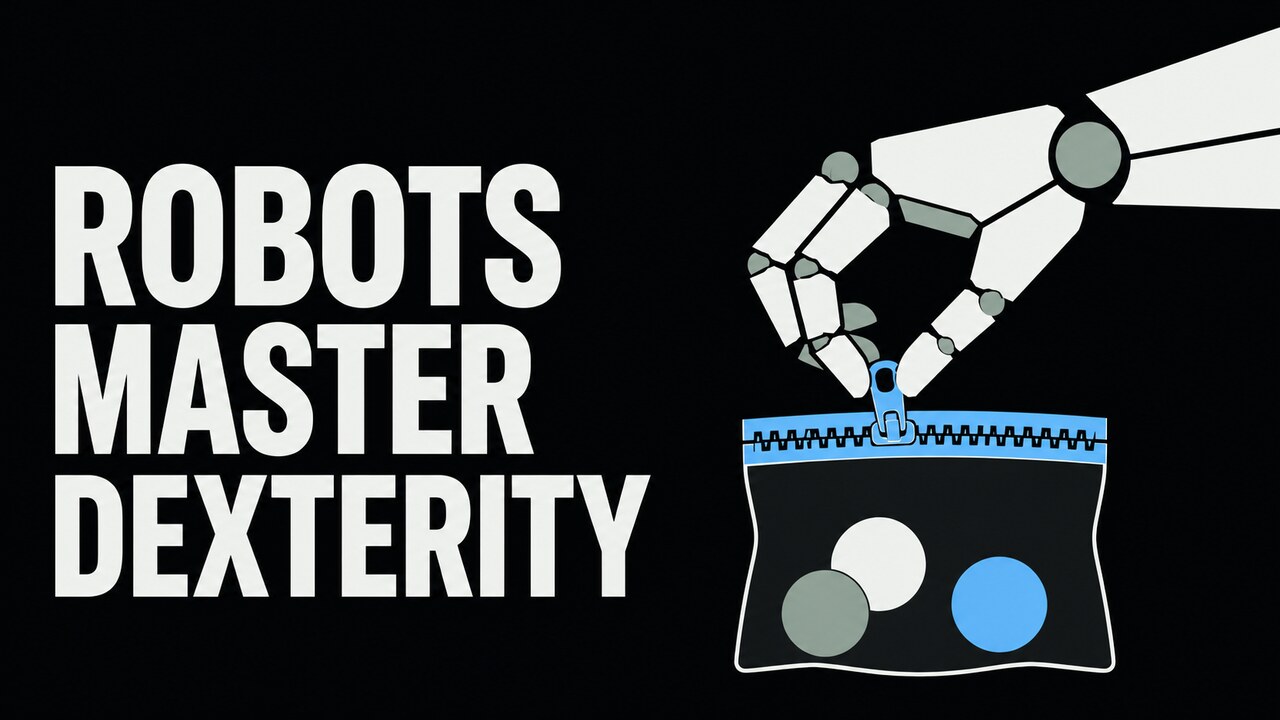
End effectors can include grippers, hands, suction devices or specialized tools. Their design determines which contacts and actions a robot can perform, such as holding a flexible item or turning a small object.
Useful manipulation depends on more than the tool alone. Sensing, motion control, contact forces and the object's properties affect success, so a tool that works for one task or object may not work equally well for another.
ELI5
An end effector is the robot's working hand or tool: the part that directly touches or acts on what it is handling.
For example, a soft gripper and a narrow pinching tool can suit different objects even when they are attached to the same robot arm.
Must an end effector look like a human hand?
No. It can be a simple gripper, a suction device or another tool designed for the required interaction.
Does a capable tool guarantee a successful task?
No. The robot also needs suitable sensing and control, and the object's shape and material can change the difficulty.