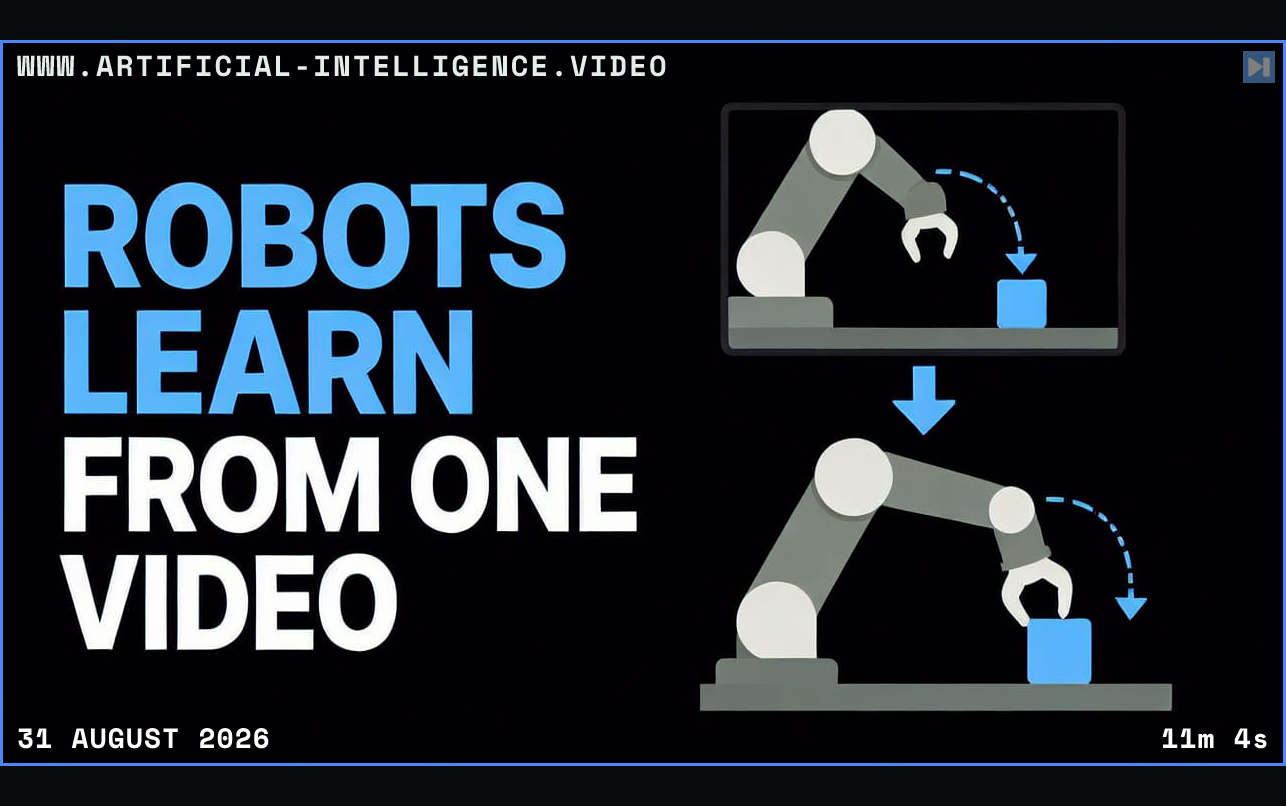
AI Copium describes S1 as a robotics foundation modelA robotics foundation model is a broadly trained model that can support many physical tasks, robot platforms, or operating environments. that learns a task from one video demonstrationImitation learning trains an agent to perform a task by learning from demonstrations of behavior rather than relying only on an explicitly written reward function. at inference time. The model treats the video as context rather than fine-tuning its weights, extending the in-context learningIn-context learning is the ability of a model to infer how to perform a task from examples or instructions supplied in its current context. pattern associated with language models into physical action.
Skilled AI reports that S1 reached 66 percent on unseen long-horizon tasksTask generalization is the ability of a model to apply learned intent or skills successfully to unfamiliar examples and conditions. while a language-conditioned comparison reached about 9 percent. Demonstrations include flipping a pancake, watering a plant with a substitute container, topping off an already full glass and ignoring an accidental dropped egg, which suggests the model is following task intent rather than copying motion blindly.
The video argues that one-shot demonstrationsOne-shot learning is the ability of a model to recognize or perform a new task after receiving only one labeled example or demonstration. could reduce the cost and time needed to teach robots new industrial jobs. It also treats the evidence cautiously because the benchmarks and scaling claims come from Skilled AI and still need validation in broader real-world deployments. The closing request to like, subscribe and comment is omitted.
 Watch on YouTube